How to Choose a Robot Cell in 2026?

Choosing a robot cell in 2026 is not simply a matter of selecting the fastest robot. It is a production decision involving people, materials, software, safety, and future demand. Joseph Engelberger, widely regarded as the father of industrial robotics, once said, “I can’t define a robot, but I know one when I see one.” His practical view still matters. A robot cell must be judged by its real performance on the factory floor.

Start with the task. Measure cycle time, payload, reach, part variation, changeover frequency, and operator interaction. A cell that handles a metal housing today may struggle with reflective surfaces tomorrow. Check the gripper, vision system, conveyor, controller, and maintenance access as one system. They are not isolated purchases. Ask whether technicians can diagnose faults from a clear interface, with a torque wrench and spare cables nearby.

Safety deserves careful attention. Risk assessments, guarding, emergency stops, access control, and validated operating procedures should be designed before installation. Local requirements still apply. So do site-specific hazards. A supplier’s standard package may not fit your floor, workflow, or workforce.

The financial model should include integration, training, downtime, tooling, energy, and software updates. Payback alone can mislead. Reliability matters more when one failed sensor can stop a whole line.

There is no perfect robot cell. That is uncomfortable, but useful. Pilot the most uncertain operation first. Test poor lighting, dusty parts, awkward loading, and rushed changeovers. Then revise the design before a costly commitment.
How to Choose a Robot Cell in 2026?

Define the Production Need and Robot Cell Objectives

How to Choose a Robot Cell in 2026?

Define the Production Need and Robot Cell Objectives

A robot cell should solve a measured production problem, not simply add automation. Start with the product, process, and expected output. Record cycle time, takt time, part weight, dimensions, and changeover frequency. Observe the line during busy and quiet periods. Real conditions often differ from planning spreadsheets.

Set clear objectives before comparing cell designs. You may need higher throughput, steadier quality, safer material handling, or fewer repetitive tasks. Define acceptable cycle time and maximum variation. Check robot reach, payload, tooling space, operator access, and maintenance clearance. A cell that fits the robot may not fit the real workflow. Leave room for inspection and future process changes.

Tips: Walk the proposed cell area with a tape measure. Mark the operator’s standing position, material bins, doors, and emergency access. Test the heaviest part and the longest tool path. Ask operators where delays actually occur. Their experience can reveal hidden handling problems. A first estimate is rarely perfect. Keep assumptions visible, and revise them after a small pilot. Confirm the risk assessment, guarding, control logic, and applicable safety requirements with qualified professionals. Good objectives should be measurable, but some production data may remain uncertain. That is worth recording, not disguising.

Compare Robot Cell Types, Layouts, and Workspace Requirements

Choosing a robot cell in 2026 starts with the workspace, not the robot arm.

Fixed cells suit repeatable welding, assembly, and packaging. They need guarded floorspace, access doors, tooling clearance, and maintenance paths.

Collaborative cells can reduce guarding, but they still require risk assessment under ISO 10218 and ISO/TS 15066.

Mobile cells offer flexibility, yet charging areas, floor conditions, and navigation routes become critical.

Industry demand remains strong. The International Federation of Robotics reported 541,302 industrial robots installed worldwide in 2023, with more than 4.28 million operating robots globally. This growth makes layout planning less forgiving.

Measure the full reach envelope, not only the arm’s working radius. Include grippers, cables, pallets, operator movement, and emergency access. A six-axis arm may fit on paper but collide with a conveyor or inspection station. I have seen layouts fail because maintenance space was treated as unused space.

Tips: Mark the cell on the factory floor with tape before purchasing equipment. Test operator reach, pallet exchange, and tool changes. Keep at least one clear service route. Verify payload at maximum reach, not at the catalog’s ideal position. Leave room for future sensors or a second fixture. A smaller cell can be efficient, but cramped access creates delays and unsafe workarounds. The best choice may still be imperfect. Recheck it with operators and maintenance technicians.

Sources: IFR World Robotics 2024; ISO 10218; ISO/TS 15066.

Evaluate Payload, Reach, Speed, and Required Robot Capabilities

How to Choose a Robot Cell in 2026?

Payload is more than the product’s listed weight. Add grippers, cables, fixtures, and acceleration forces. A 20-kilogram load may require a 35-kilogram robot. The International Federation of Robotics reported 541,302 industrial robot installations in 2023. This growth makes correct cell sizing increasingly important.

Reach should include the entire work envelope, not only the farthest pick point. Measure approach angles, fixture height, conveyor position, and maintenance access. A practical test uses a cardboard mock-up before purchasing equipment. Speed also needs context. Faster motion can reduce cycle time, but it may increase vibration, settling time, and safety distance. Small errors become expensive.

Payload, reach, and speed are only the starting points. Confirm whether the robot supports force sensing, vision integration, coordinated motion, cleanroom operation, or precise path control. The required capability should match the task. Do not pay for unused complexity. Leave margin. The IFR’s World Robotics 2024 report recorded about 4.28 million industrial robots operating worldwide in 2023, yet availability depends heavily on integration quality. A cell can meet every catalog specification and still miss production targets. I have seen planning models ignore tool changes and operator access. That assumption rarely survives commissioning. Evaluate the complete work cycle, including loading, inspection, recovery, and planned maintenance.

How to Choose a Robot Cell in 2026? – Evaluate Payload, Reach, Speed, and Required Robot Capabilities

Typical engineering ranges for selecting a robot cell. Final specifications should be validated against the complete workpiece, tooling, layout, safety, and cycle-time requirements.

Application Profile Typical Payload
(kg)
Recommended Reach
(mm)
Typical TCP Speed
(m/s)
Position Repeatability
(mm)
Common Robot Configuration Required Robot Capabilities Cell Design Priorities
Small-Part Assembly 1–5 500–900 1.0–3.0 ±0.02–0.05 4–6 axis articulated or compact SCARA High repeatability, precise insertion, force or torque feedback, vision guidance, and reliable end-of-arm tooling control. Stable fixtures, controlled part presentation, low vibration, and accurate calibration.
Machine Tending 5–20 800–1,500 1.5–2.5 ±0.03–0.08 6-axis articulated robot Door and chuck or fixture interfacing, automatic tool-change support, part-presence detection, and process-status communication. Clear loading paths, chip and coolant protection, safe access, and synchronized machine-to-robot signals.
High-Speed Pick and Place 3–15 600–1,400 2.0–4.0 ±0.03–0.08 4-axis delta, SCARA, or compact articulated robot Fast acceleration, short settling time, conveyor tracking, vision-based location correction, and lightweight tooling. Minimize travel distance, optimize part flow, reduce gripper mass, and verify throughput under real product spacing.
Arc Welding 5–15 1,200–2,000 1.0–2.0 ±0.03–0.08 6-axis articulated robot Smooth coordinated motion, torch cable management, weld-path control, seam tracking, and process-parameter integration. Rigid fixtures, fume extraction, controlled torch orientation, spatter protection, and adequate access around joints.
Palletizing and Case Handling 20–80 1,600–3,200 1.5–2.5 ±0.05–0.10 4-axis palletizing or 6-axis articulated robot High wrist load capacity, pattern generation, pallet-position management, coordinated conveyor signals, and collision monitoring. Floor space, pallet exchange, product stability, gripper vacuum capacity, and ergonomic material flow.
Heavy Material Handling 80–250 2,000–3,500 0.8–1.8 ±0.05–0.15 Heavy-payload 6-axis articulated robot High static and dynamic payload capacity, overload monitoring, rugged wrist construction, multi-axis coordination, and safe recovery functions. Structural reinforcement, inertia verification, guarded access, lifting-point design, and safe payload transfer.
Human-Accessible Collaborative Task 3–20 600–1,800 0.5–1.5 ±0.03–0.10 6-axis collaborative articulated robot Force and torque sensing, speed and separation monitoring, hand-guiding, configurable safety limits, and easy operator interaction. Risk assessment, pinch-point control, protective device integration, ergonomic reach zones, and validation of operating modes.
Inspection and Vision-Guided Handling 2–20 800–1,800 0.8–2.0 ±0.02–0.08 4–6 axis robot with integrated vision Camera synchronization, repeatable positioning, lighting compatibility, calibration management, defect classification, and traceability data exchange. Consistent lighting, controlled backgrounds, stable inspection distance, data connectivity, and sufficient dwell time for image processing.
Selection checks: Include the workpiece, gripper, cables, adapters, and transferred payload in the payload calculation. Confirm wrist inertia, center-of-gravity limits, reach at every required orientation, access to maintenance points, and the actual cycle time under production conditions. A practical preliminary design normally reserves approximately 20–30% payload capacity for variation and dynamic effects, subject to the robot manufacturer’s load specifications and application analysis.

Assess Safety Systems, Integration, Programming, and Maintenance

How to Choose a Robot Cell in 2026?

Assess Safety Systems, Integration, Programming, and Maintenance

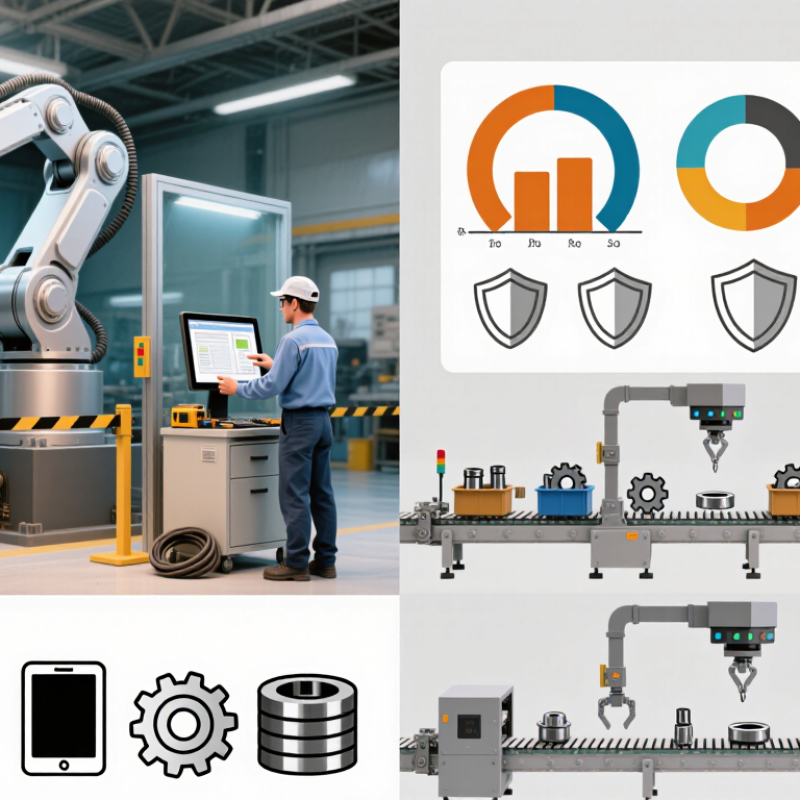
In 2026, choosing a robot cell means examining the entire work process, not only the robot’s reach. During commissioning, I check guarded access, emergency stops, interlocked doors, and light curtains. Each device should be easy to test and clearly visible to operators. Test every stop. A safe cell should also control restart conditions, so motion cannot resume unexpectedly after an interruption.

Integration often decides whether a cell performs reliably. Confirm communication between the robot, controller, sensors, conveyors, and production software. Review input and output lists before installation. A loose cable or unclear signal can stop an entire shift. I prefer simple status screens showing faults, cycle steps, and operator actions. Complex screens look impressive, but they slow troubleshooting.

Programming should support controlled speed changes, clear error messages, and practical recovery routines. Ask whether trained maintenance staff can adjust a position without rewriting the whole program. Maintenance planning needs equal attention. Check access to grease points, electrical cabinets, tooling, and replaceable sensors. Record inspection intervals and keep critical spares identified. I once underestimated cleaning time around a vision sensor. That was uncomfortable. The cell met its cycle target, yet maintenance disliked using it. A short trial with real operators may reveal this weakness before production begins.

Calculate Total Cost, Scalability, and Long-Term Operational Value

How to Choose a Robot Cell in 2026?

Calculate Total Cost, Scalability, and Long-Term Operational Value

A robot cell should be judged by its working life, not its purchase price. Include the robot, tooling, fixtures, safety equipment, programming, installation, training, and floor preparation. Add electricity, preventive maintenance, spare parts, software updates, and expected downtime. A simple spreadsheet can reveal surprising costs. For example, a cell costing $140,000 may require another $35,000 for integration and commissioning. Its real value depends on stable cycle times, low scrap rates, and reliable output over several years.

Scalability matters when product demand changes. Choose a layout with accessible service areas and room for material flow improvements. Modular grippers, quick-change tooling, and expandable control systems can reduce future redesign costs. Track practical measures, including uptime, mean time between failures, changeover minutes, and labor hours per unit. In my experience, teams often overestimate daily production. Breaks, quality checks, minor jams, and operator learning reduce theoretical capacity. That gap deserves honest planning.

Tips

Request a five-year total-cost model. Test the cell with real parts, not ideal samples. Ask who maintains the system after installation. Keep a budget for unexpected integration work. I have seen small alignment problems create weeks of delays. Do not ignore operator feedback; the safest design may not be the fastest one. Review energy use and maintenance records every quarter. A cell that performs well today can become expensive when its controls, sensors, or tooling no longer support new products.

Login